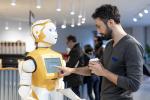
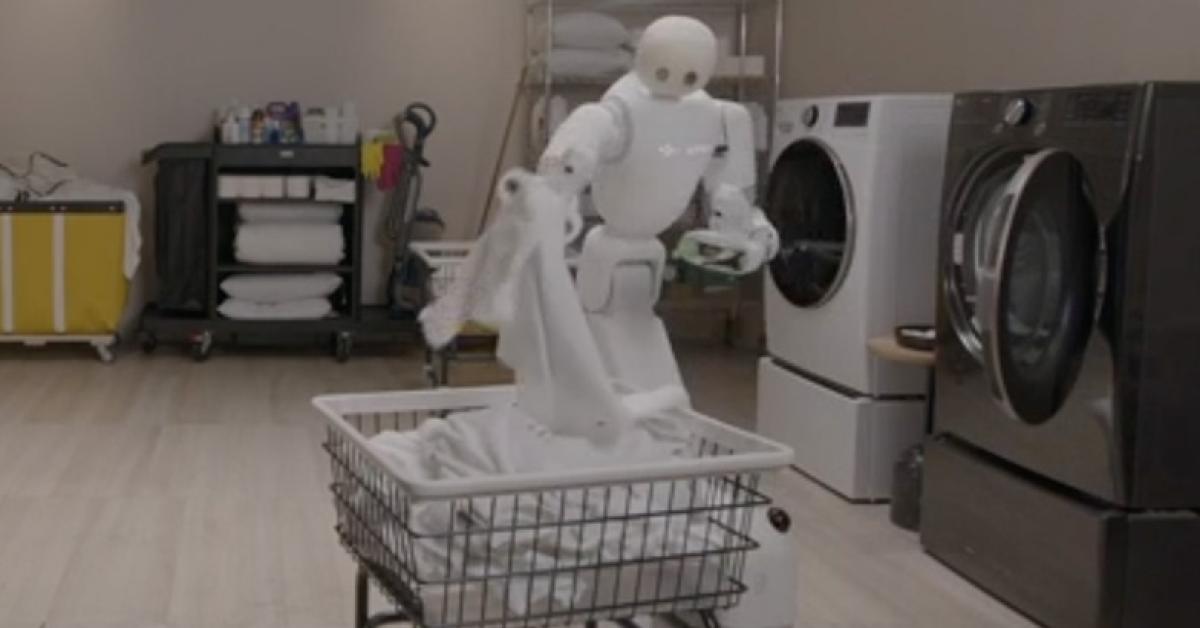
REDWOOD CITY, Calif. — DYNA Robotics recently launched the DYNA 2.1 physical agent, a semi-humanoid robot powered by DYNA’s proprietary model that can autonomously complete entire physical workflows — like a commercial laundry shift — without human intervention, performing tasks that demand both physical dexterity and complex reasoning.
DYNA 2.1 is being deployed in hotels, laundromats and restaurants.
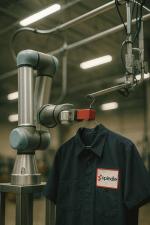
DYNA’s proprietary semi-humanoid hardware includes an upper torso with two arms compatible with parallel-jaw grippers or dexterous hands to reach and manipulate objects, plus four steerable wheels that let it move around easily without risking a topple.
To manage continuous, hours-long shifts, the robot uses a vision-language orchestrator to reason through complex workflows and a whole-body controller to coordinate driving, reaching, bending, and lifting into one fluid action.
It is underpinned by DYNA’s proprietary world action model DYNA 2, trained on a million hours of human and robot data to handle physical skills and maneuverability.
“Our goal is to make general-purpose robots commercially viable for real-world scenarios,” says Lindon Gao, co-founder and CEO of Dyna Robotics.
“Our customers need robots that complete an entire workflow for a full shift — without human babysitters — not just specific tasks.”
The DYNA 2.1 physical agent can manage an entire commercial workflow end-to-end, such as food preparation, data center management, and commercial laundry.
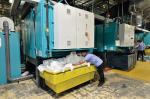
For example, in a commercial laundry setting, DYNA 2.1 can complete an entire shift, including:
- Loading the washer and dryer and turning the machines on.
- Bending to reach the very back of a dryer to unload bulk towels into a basket.
- Snapping towels flat, folding them, and organizing them into specific stacks by size.
- Crouching to place finished stacks on bottom shelves or reaching up to place them on top shelves.
- Autonomously correcting physical errors — such as picking up a dropped towel from the floor or abandoning a bad grasp to try again — without requesting human help.
DYNA 2.1 is optimized for Mean Time Between Interventions (MTBI), or how long the machine operates before a human must step in to assist.
The physical agent captures execution data as it operates — from the reasoner’s decision traces to the controller’s joint loads. This data feeds back into the system, creating a continuous improvement loop designed to steadily increase the minutes of work achieved per intervention.
“This is a far more useful benchmark than per-episode success rates on isolated tasks, which is widely used today but fails to reflect true commercial viability,” says co-founder Jason Ma.
“Continuous real-world shifts require thousands of sequential steps, which is why we measure MTBI to ensure our robots are commercially viable and can operate without human babysitters.”
Have a question or comment? E-mail our editor Matt Poe at [email protected].